Ten-Link Robot Snake CAD Prototype
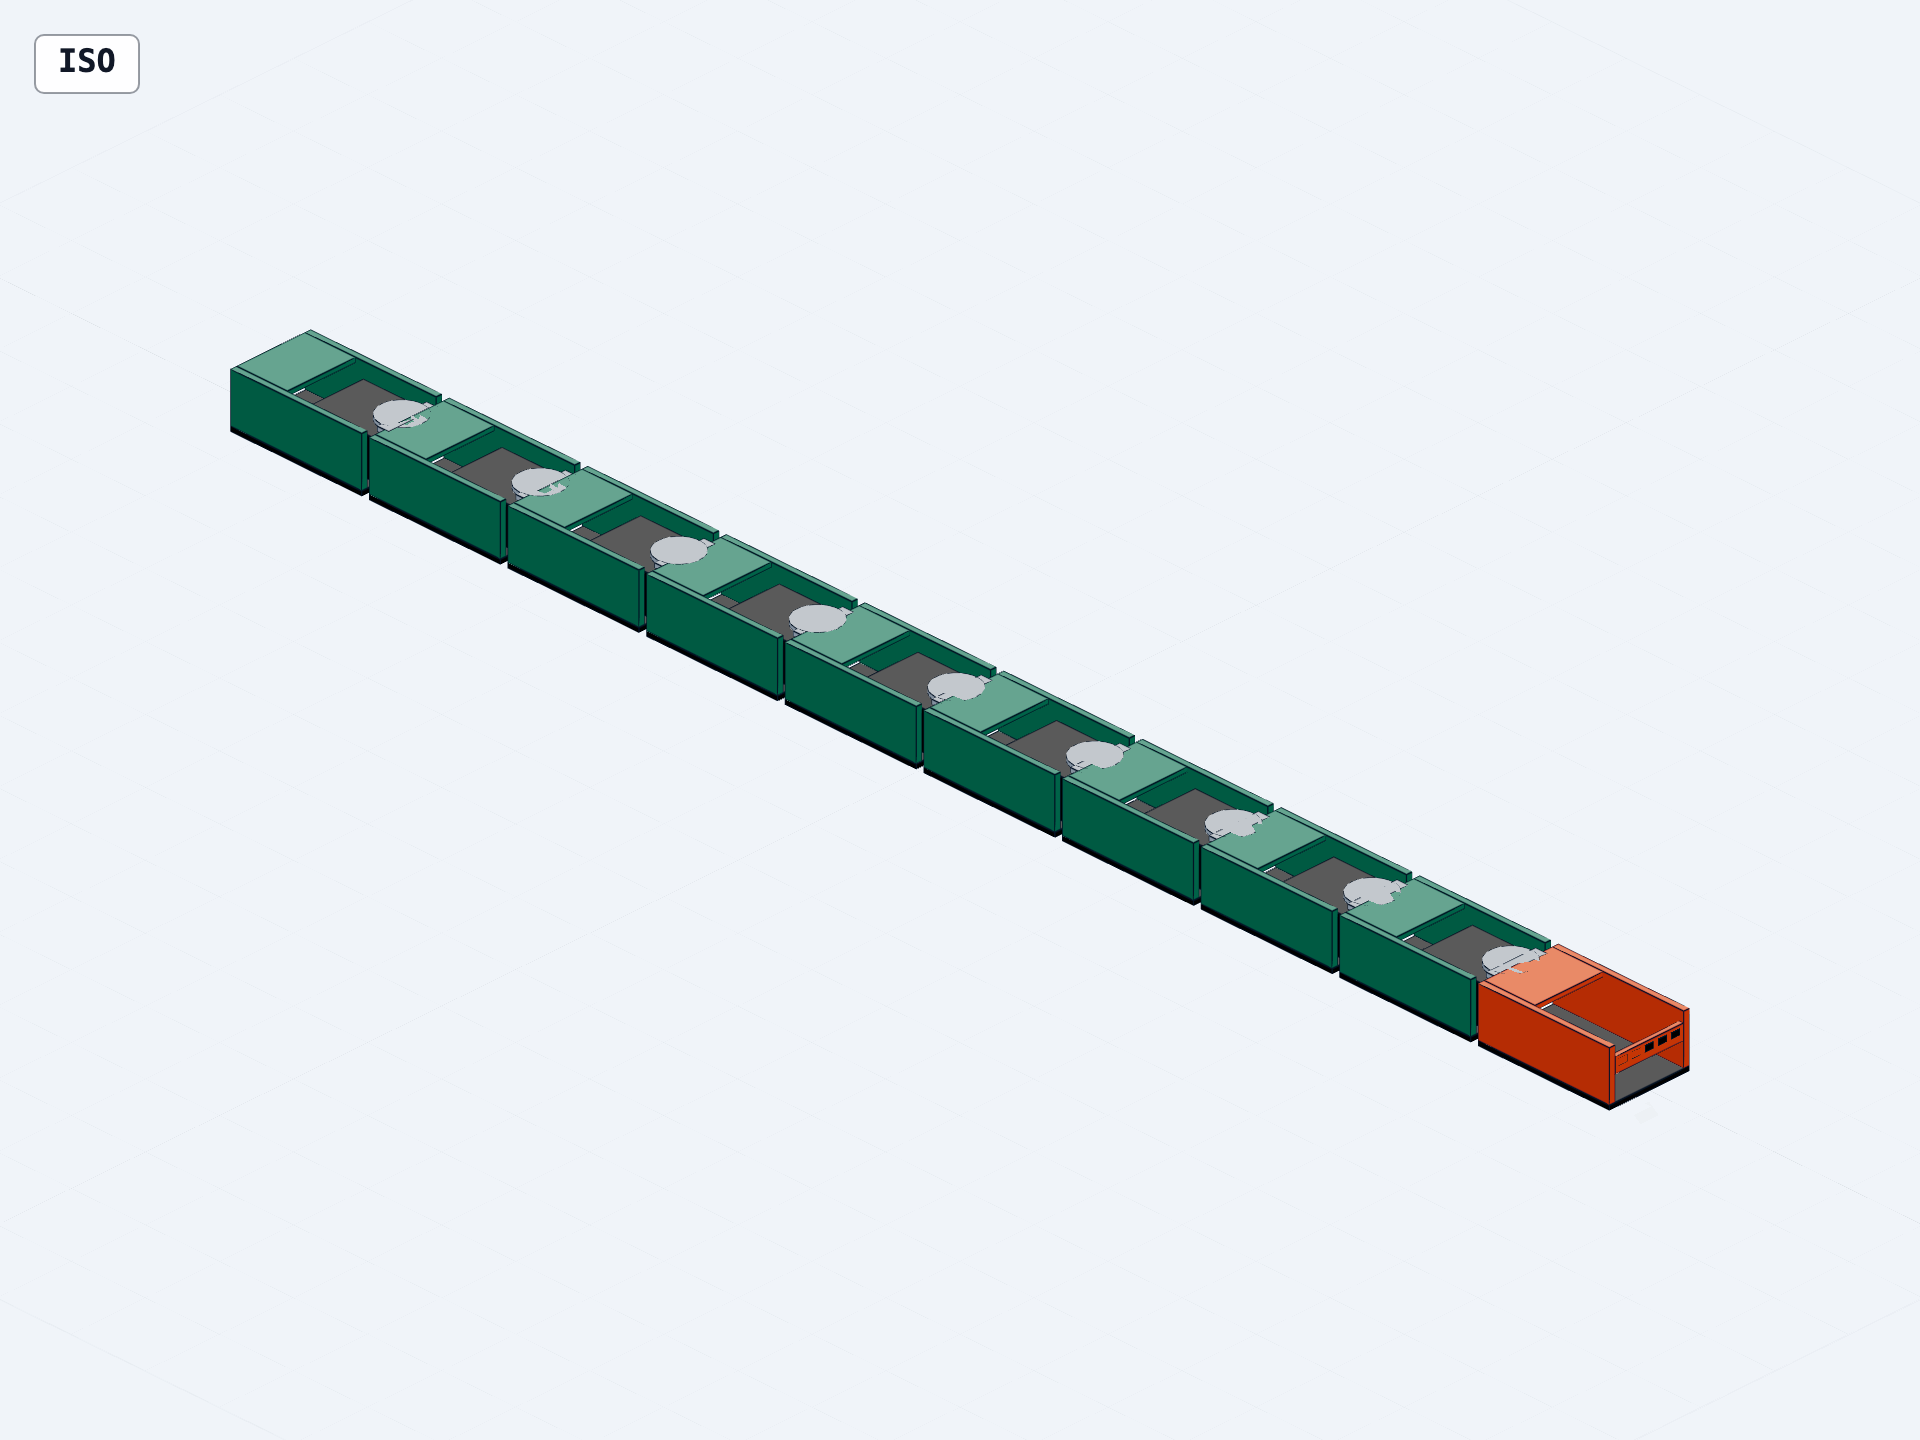
Create an editable ten-link articulated robot-snake assembly with engineering source, a STEP model, and a browser-inspectable 3D preview.
How it was made
The publisher’s ingredients and steps. Unlisted details are unknown. Copy this text kit to your agent to adapt it.
Models
- GPT-5.6 · OpenAI · execution · Codex
Agent
Codex
Pinned skills
- earthtojake/text-to-cad/skills/cad ↗Commit
fdbb4b4fb62d95ae298cfe9a46fdc7092bdaf423 - earthtojake/text-to-cad/skills/cad-viewer ↗Commit
fdbb4b4fb62d95ae298cfe9a46fdc7092bdaf423 - arpitg1304/robotics-agent-skills/skills/robotics-design-patterns ↗Commit
54f7b578f3dc269d29c0beb623b3f2611fd3a430 - arpitg1304/robotics-agent-skills/skills/robotics-testing ↗Commit
54f7b578f3dc269d29c0beb623b3f2611fd3a430
References
- Published brief and result ↗document
Existing result context and its stated limits.
- Recorded execution prompt ↗document
Original reusable prompt; preserved unchanged.
Tools and APIs
- CAD tooling
Create parametric link geometry and STEP exports requested in the published prompt.
- CAD Viewer
Inspect the assembly through the CAD-viewer skill selected in the manifest.
Ordered steps
Bound the prototype
Reconstructed workflow from the published prompt and available result artifacts; this is not a recorded sequence of agent turns. Use the published prompt to define ten repeating links and joint interfaces in a shallow alternating curve; keep the scope to digital geometry.
Build the linked assembly
Create editable parametric source and a ten-link STEP assembly, then export a GLB preview and the three documented camera views.
Inspect the exports
Follow the prompt checks for link count, solids, spacing and reopening. The existing preview demonstrates inspectable geometry, not locomotion, strength or physical performance.
About
Create an editable ten-link articulated robot-snake assembly with engineering source, a STEP model, and a browser-inspectable 3D preview.
Original request
Make a digital prototype of a snake robot.
Exact prompt
Hidden characters, if present, appear as Unicode escapesCreate a digital CAD prototype of a ten-link articulated robot snake. Model one repeatable link body and the joint interfaces needed to assemble ten links into a shallow alternating curve. Keep the design bounded to inspectable geometry and assembly structure; do not add electronics, actuators, batteries, sensors, firmware, networking, skins, or decorative subsystems.
Deliver editable parametric CAD source, a complete STEP assembly, a browser-inspectable GLB preview, and clear isometric, opposite-isometric, and top-view renders. Preserve units and named dimensions. Verify that the exported assembly contains all ten links, that each link remains a valid solid, that the joint spacing is consistent, and that the final files reopen successfully.
Treat this as a digital geometry prototype only. Do not claim locomotion, dynamics, controller performance, collision behavior, printability, strength, tolerances, manufacturability, calibration, safety, or real-world performance. Do not command physical equipment or deploy robot software. State which physical, kinematic, actuation, control, and sim-to-real questions remain unresolved.Technical details and provenance
- Provider
- OpenAI
- Model
- GPT-5.6
- Agent
- Codex
- Published
- Publication
- community